




232 Gongneung-ro, Nowon-gu, Seoul, 01811, korea
Tel : +82-2-970-6114,7114 Fax : +82-2-970-6088
Tel : +82-2-970-6114,7114 Fax : +82-2-970-6088

 X
 Research Spotlight
| Title | Researchers Develop Energy-Saving TPMS Feet for Quadruped Robots | ||||
|---|---|---|---|---|---|
| Writer | 국립대학육성사업추진단 | ReadCount | 845 | Date | 2026-07-23 |
| Files |
|
||||
|
Compressible 3D-printed TPMS feet , when paired with a deep reinforcement learning controller, cut power consumption by up to 6.2%
Quadruped robots consume more energy than wheeled robots, limiting how long they can operate. Researchers developed compressible 3D-printed porous foot pads that act like springs, storing and releasing mechanical energy during walking. Combined with a deep reinforcement learning controller that learns energy-efficient movements, the system reduced robot power consumption by up to 6.2%.
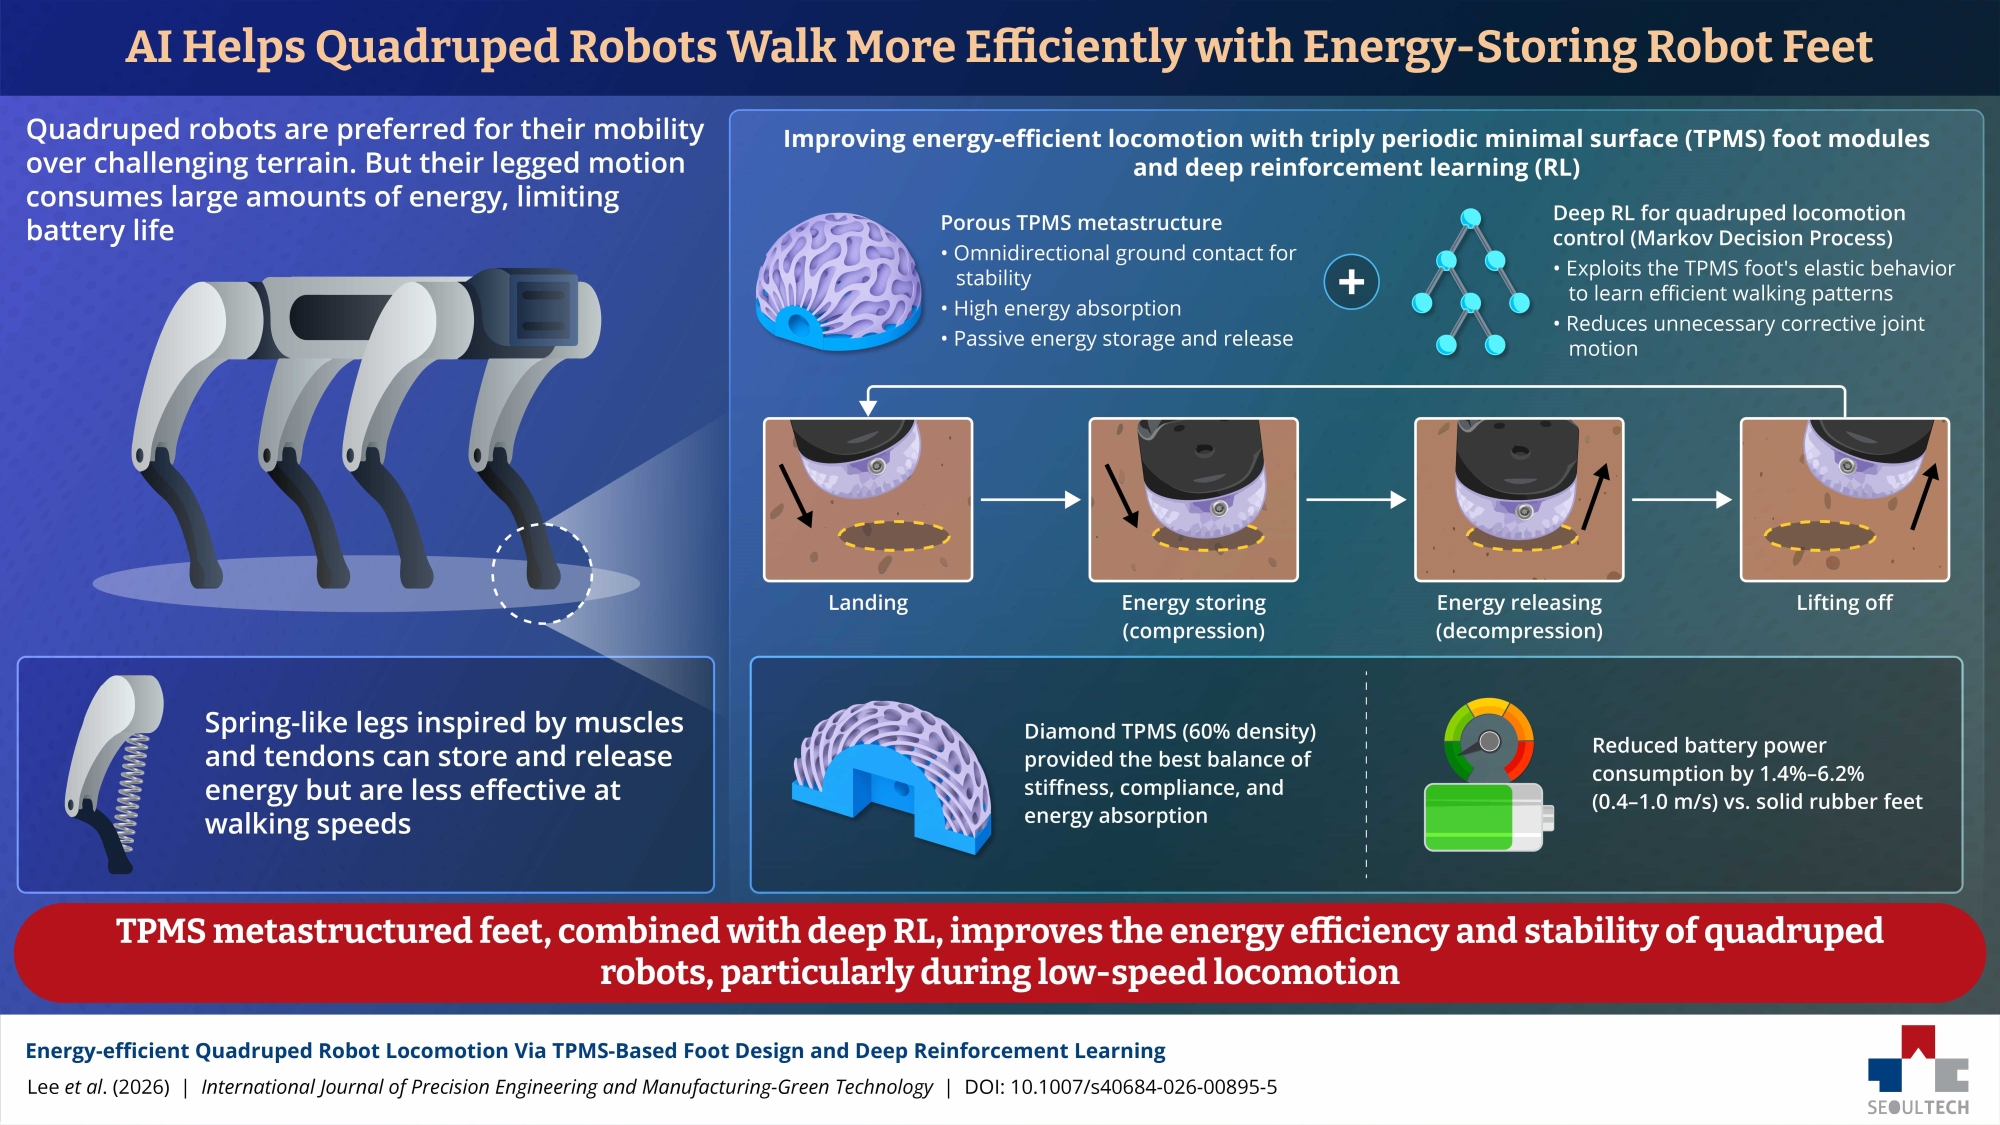
Title: AI-optimized robot footpads improve quadruped robot energy efficiency Caption: Porous 3D-printed triply periodic minimal surface (TPMS) metastructure footpads store and release impact energy during walking. Combined with a deep reinforcement learning controller, they reduced battery power consumption by up to 6.2%. Credit: Dr. Jung-Yup Kim and Dr. Keun Park from Seoul National University of Science and Technology, Korea License type: Original content Usage restrictions: Cannot be reused without permission
Quadruped robots, which walk on four legs, are increasingly used for tasks such as inspection, transportation, and search-and-rescue operations. However, their repeated leg movements consume far more energy than the rolling motion of wheeled robots, making it challenging to improve energy efficiency. One strategy to reduce energy consumption is to use springs or other elastic components in the limbs to store impact energy when the foot lands and release it during push-off. However, at low walking speeds, much of this stored energy is dissipated rather than contributing to forward motion, reducing efficiency and potentially destabilizing the robot.
Addressing this challenge, Dr. Keun Park and Dr. Jung-Yup Kim at the School of Mechanical System Engineering, Seoul National University of Science and Technology, Republic of Korea, have developed porous triply periodic minimal surface (TPMS) robot feet that store and release impact energy. They paired these compliant feet with a deep reinforcement learning controller that learned how to exploit the elastic energy stored in the feet while walking. Together, the approach reduced battery power consumption by up to 6.2% at walking speeds between 0.4 and 1.0 meters per second.
The study was made available online in the International Journal of Precision Engineering and Manufacturing-Green Technology on May 05, 2026.
“By modulating foot stiffness and leveraging passive energy absorption and release, the proposed approach offers a practical alternative to conventional leg-mounted spring mechanisms,” says Dr. Park.
TPMS metastructures are lightweight porous materials made of repeating three-dimensional networks that are stiff with excellent energy-absorbing performance. Their unique mechanical properties have led to applications ranging from airless tires to soft robotic systems such as grippers and joints.
The researchers designed and 3D-printed three hemispherical TPMS foot designs—primitive, gyroid, and diamond—and evaluated their energy-storage and energy-release performance through compression tests. Out of the three designs, the diamond design with a relative density of 60% was chosen for its superior flexibility, energy absorption, and minimal energy loss.
To enable the robot to benefit from the energy-storing feet, the researchers used deep reinforcement learning. The controller evaluated different walking strategies based on how much energy they consumed, while accounting for how the TPMS feet compressed and rebounded during walking. This enabled the robot to coordinate its gait with the feet's energy storage and release, reducing the amount of work required from the motors.
The researchers then tested the trained controller on the commercially available robot equipped with the optimized TPMS feet. Compared with conventional solid robot feet, the TPMS feet reduced battery power consumption by 1.4% to 6.2% across walking speeds ranging from 0.4 to 1.0 meters per second. The robot also maintained stable locomotion, demonstrating that the controller effectively exploited the passive energy stored in the compliant feet while minimizing unnecessary corrective movements.
“These results demonstrate that TPMS metastructures, when properly modeled and exploited through learning-based control, can serve as effective energy-shaping components for energy-efficient quadruped locomotion,” says Dr. Kim.
This strategy could help develop quieter, more energy-efficient quadruped robots for indoor service, inspection, logistics, and other real-world applications.
Reference
Title: Energy-efficient Quadruped Robot Locomotion Via TPMS-Based Foot Design and Deep Reinforcement Learning Journal Name: International Journal of Precision Engineering and Manufacturing-Green Technology DOI: 10.1007/s40684-026-00895-5
About Dr. Jung-Yup Kim Jung-Yup Kim is a Professor in the Department of Mechanical Design and Robot Engineering at Seoul National University of Science and Technology, Republic of Korea. He received his B.S. and M.S. degrees in Mechanical Engineering from Inha University, Korea, in 1999 and 2001, respectively, followed by a Ph.D. in Mechanical Engineering from the Korea Advanced Institute of Science and Technology (KAIST) in 2006. His research interests include mechanical design, motion planning, and dynamics- and learning-based control of legged robots.
About Dr. Keun Park Dr. Keun Park is a Professor in the Department of Mechanical Design and Robot Engineering and Director of the Institute of 3D Printing Convergence Technology at Seoul National University of Science and Technology, Republic of Korea. He received his B.S. and M.S. degrees in Precision Engineering and Mechatronics from the Korea Advanced Institute of Science and Technology (KAIST) in 1992 and 1994, respectively, followed by a Ph.D. in Mechanical Engineering from KAIST in 1999. His research interests include finite element analysis and optimization, additive manufacturing, and the development of mechanical metamaterials.
|
|||||

Researchers Develop New Strategy for Designing Ultra-Fast Charging Batteries

Revealing Transparent Windows That Shield Buildings from Powerful Electromagnetic Pulses
